@misc{anonymous2026offsite,title={OffSite: Mobile Manipulation from a Single Scene Capture, without On-Site Teleoperation},author={{Anonymous}},year={2026},}
@inproceedings{kim2026escape,title={Escape Is Not Success: Diagnosing Spatial-OOD Failures of Robot Action Interfaces},author={Kim, Juno and Park, Yesol and Yoon, Hye-Jung and Zhang, Byoung-Tak},booktitle={CoRL Workshop on Everything Beneath the Policy},year={2026},}
@inproceedings{kim2026head2wrist,title={Head2Wrist: Wrist-Camera Robot Policies from Human Head-Camera Demonstrations without a Scene Scan},author={Kim, Juno and Park, Yesol and Yoon, Hye-Jung and Zhang, Byoung-Tak},booktitle={CoRL Workshop on UMI Arena},year={2026},}
@inproceedings{kim2026sceneq,title={Scene-Q: Confidence-Aware Coarse-to-Fine Querying of 3D Scenes with Selective VLM Reasoning},author={Kim, Juno and Park, Yesol and Yoon, Hye-Jung and Zhang, Byoung-Tak},booktitle={IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)},year={2026},note={* Equal contribution},}
@inproceedings{kim2025cdis,title={CDIS: Cross-Dimensional Class-Agnostic 3D Instance Segmentation via 2D Mask Tracking and 3D--2D Projection Merging},author={Kim, Juno and Yoon, Hye-Jung and Park, Yesol and Zhang, Byoung-Tak},booktitle={IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)},year={2025},note={* Equal contribution},}
@inproceedings{park2025dafusion,title={DA-Fusion: Deformable Attention-Based RGB-D Fusion Transformer for Unseen Object Instance Segmentation},author={Park, Yesol and Yoon, Hye-Jung and Kim, Juno and Zhang, Byoung-Tak},booktitle={IEEE International Conference on Robotics and Automation (ICRA)},pages={7490--7496},year={2025},note={* Equal contribution},}
@inproceedings{kim2024ovmap,title={OV-MAP: Open-Vocabulary Zero-Shot 3D Instance Segmentation Map for Robots},author={Kim, Juno and Park, Yesol and Yoon, Hye-Jung and Zhang, Byoung-Tak},booktitle={IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)},year={2024},note={* Equal contribution},}
@inproceedings{yoon2024seg2grasp,title={Seg2Grasp: A Robust Modular Suction Grasping in Bin Picking},author={Yoon, Hye-Jung and Kim, Juno and Park, Yesol and Lee, J.-K. and Zhang, Byoung-Tak},booktitle={IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)},year={2024},note={* Equal contribution},}
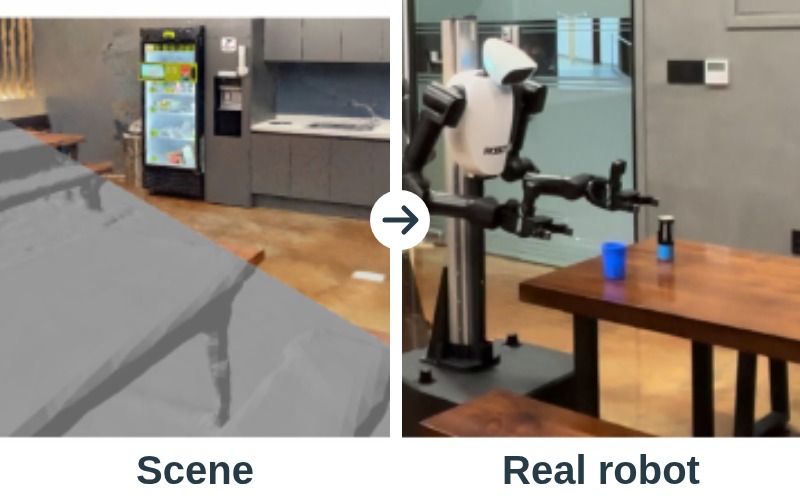 Research project, 2026
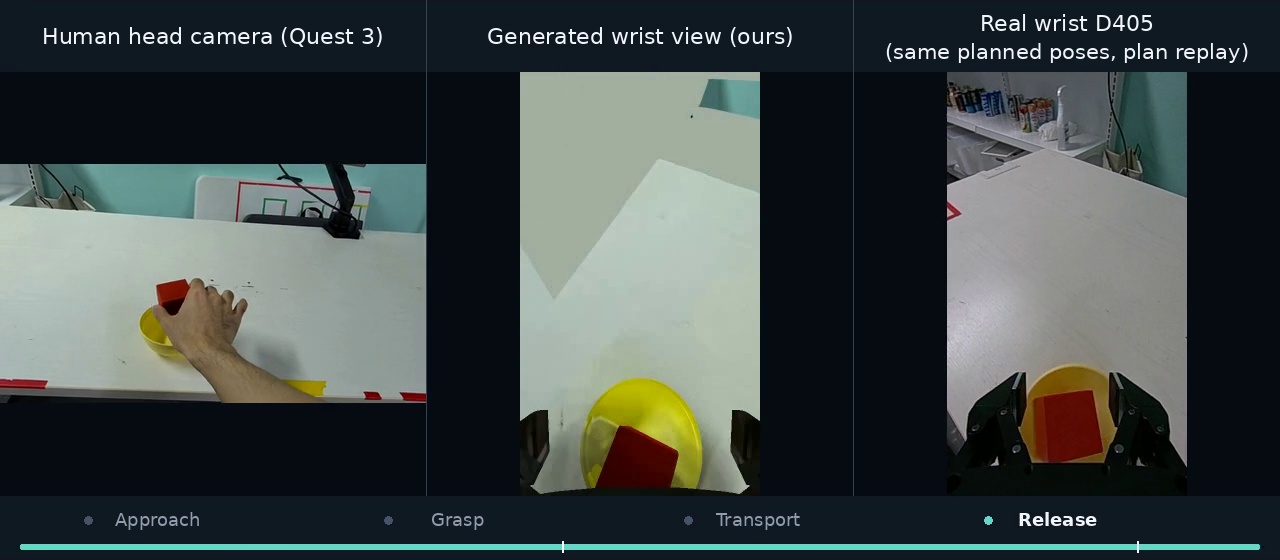 In CoRL Workshop on UMI Arena, 2026
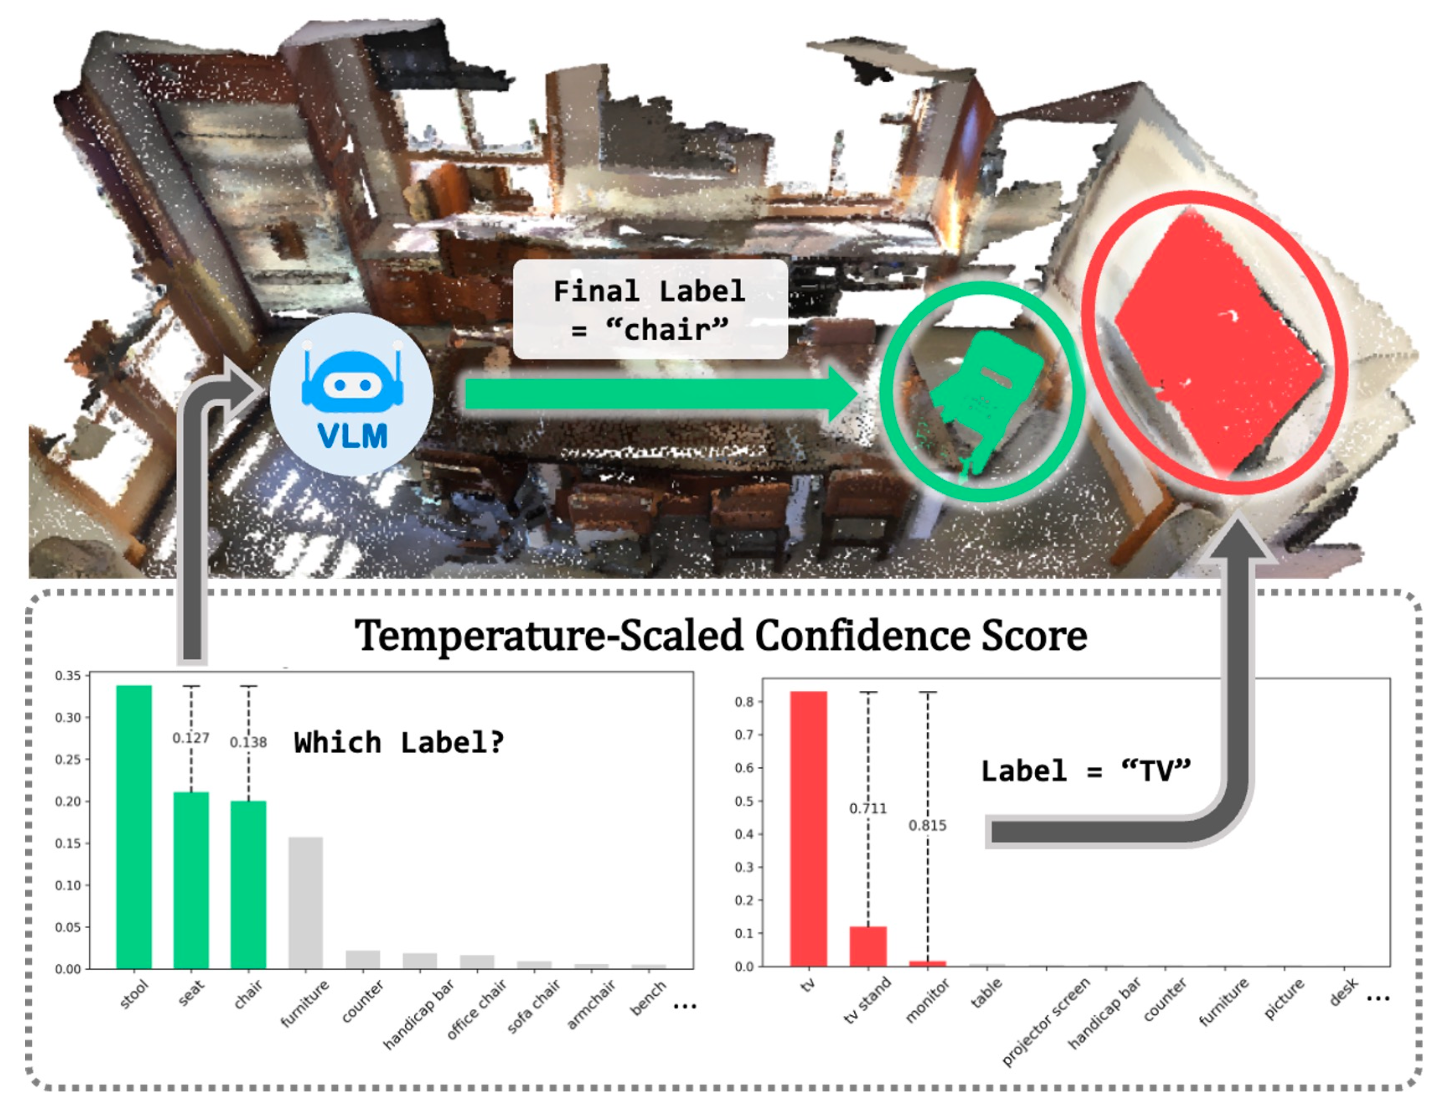 In IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2026* Equal contribution
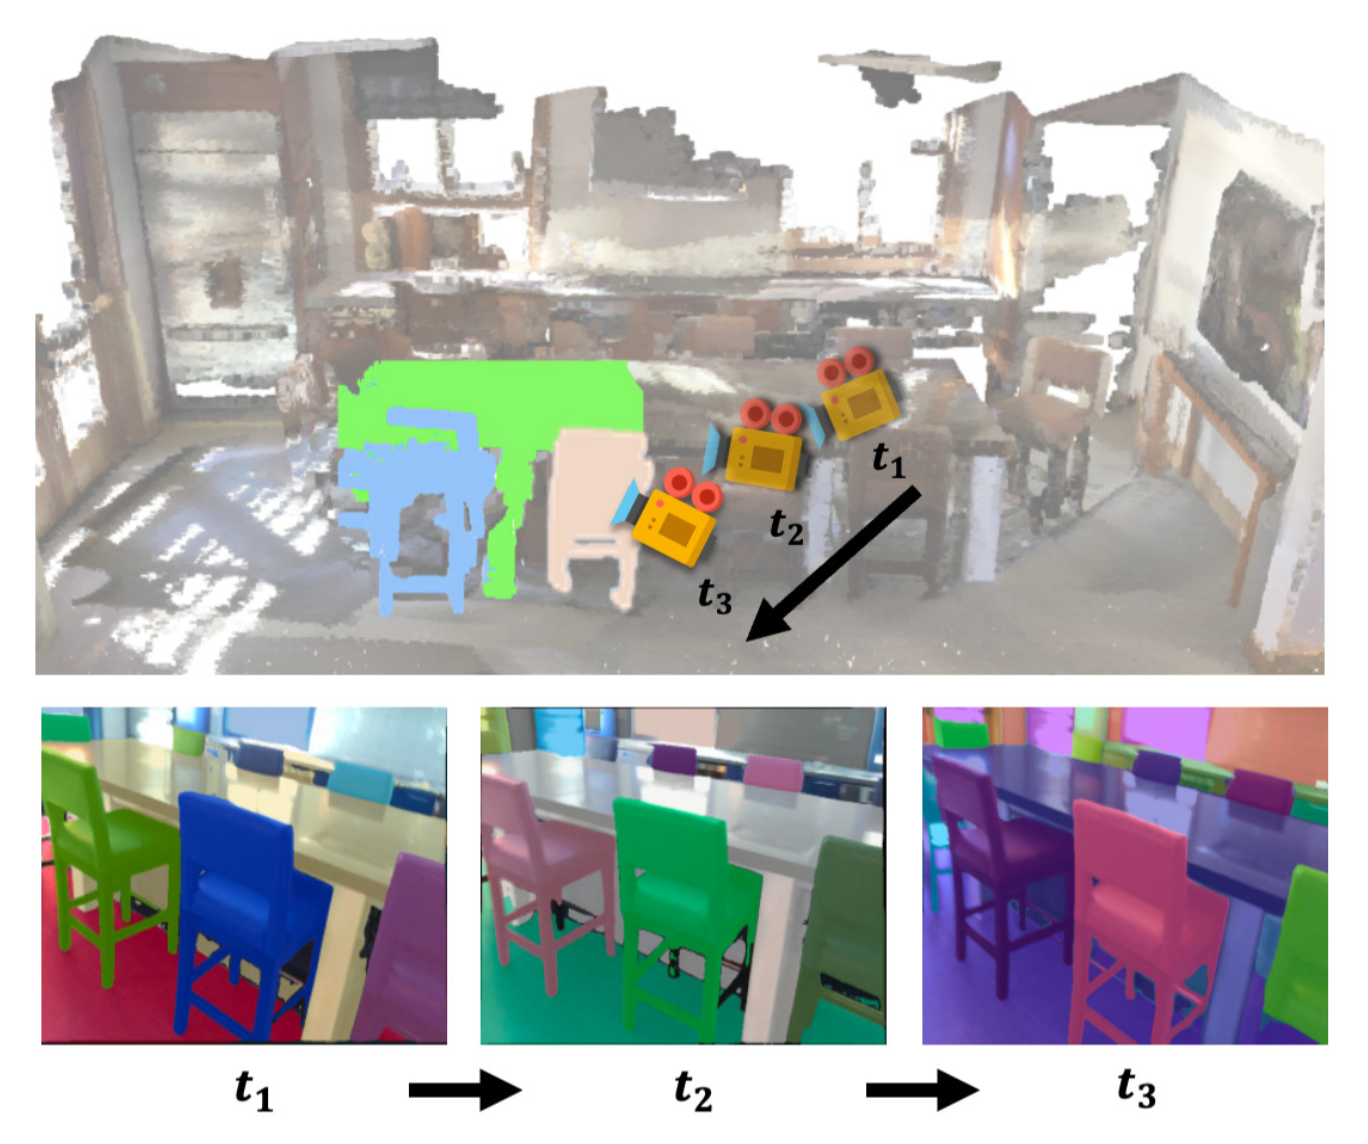 In IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2025* Equal contribution
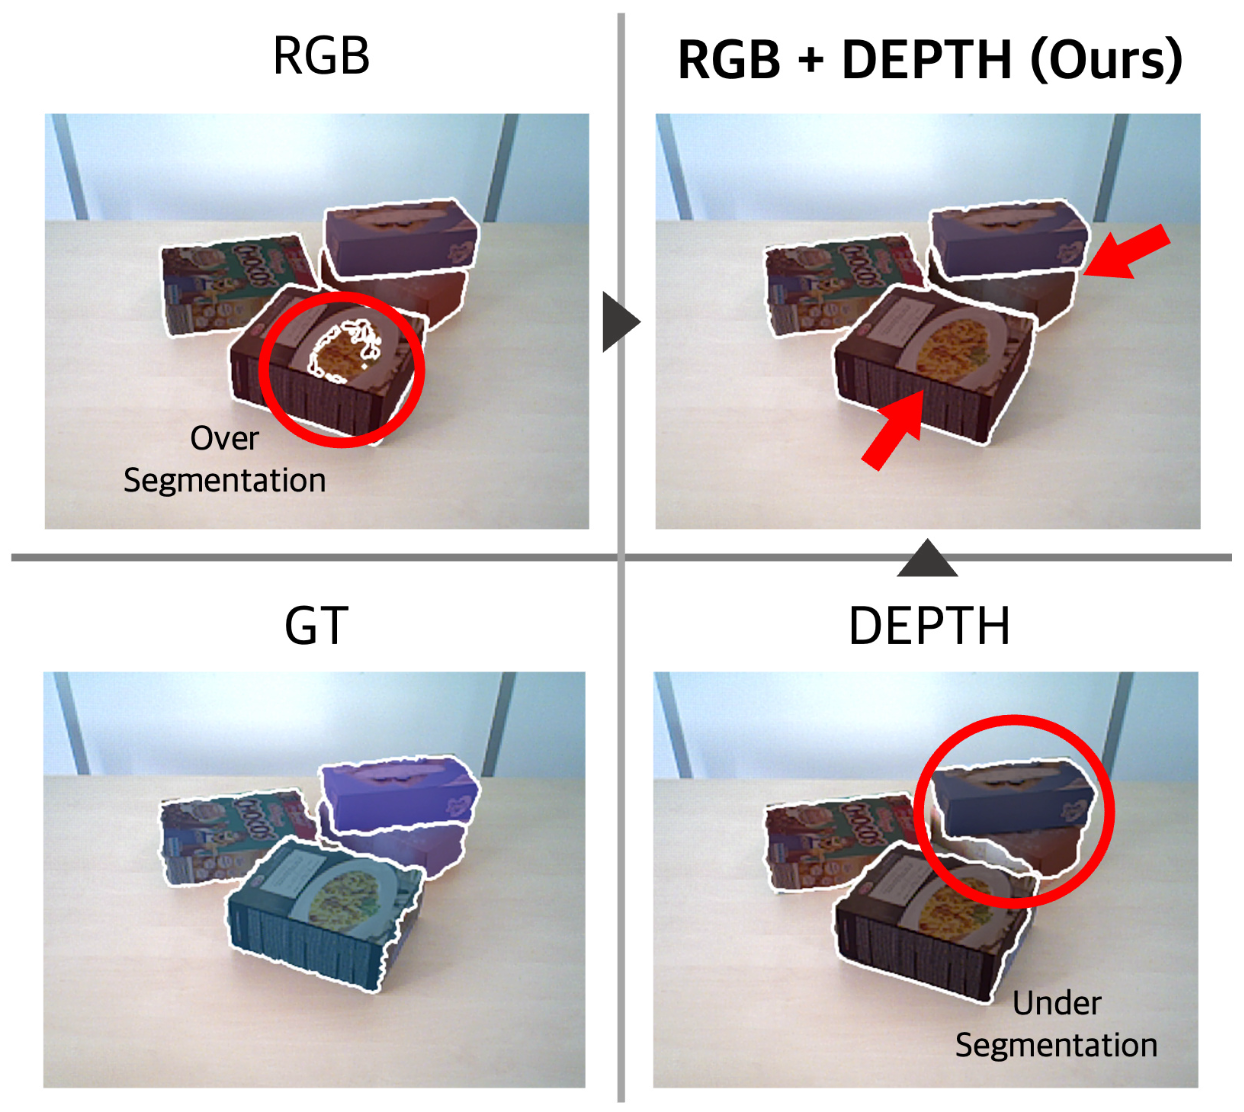 In IEEE International Conference on Robotics and Automation (ICRA), 2025* Equal contribution
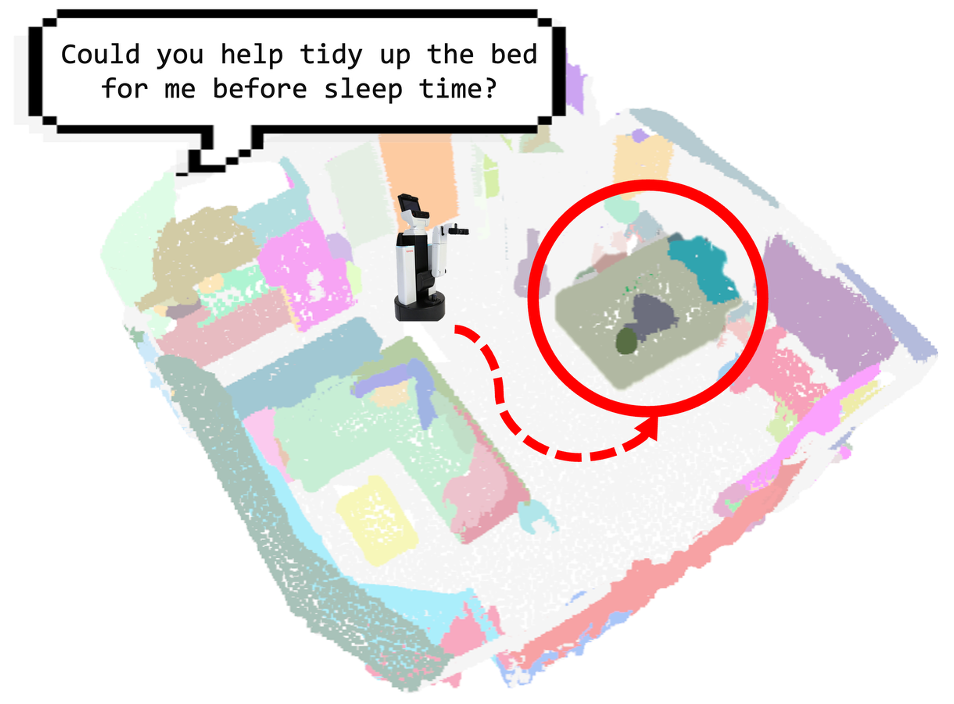 In IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) (Oral), 2024* Equal contribution
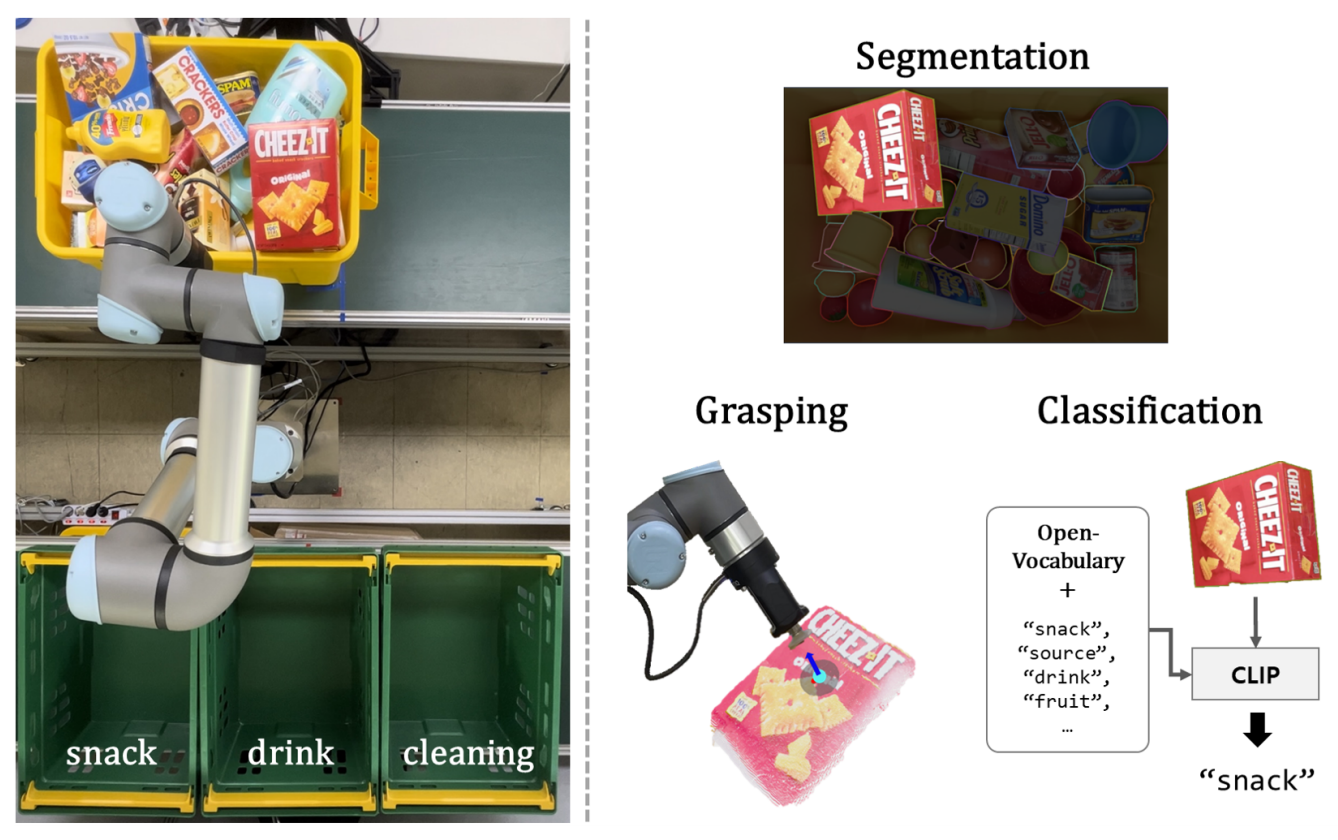 In IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2024* Equal contribution
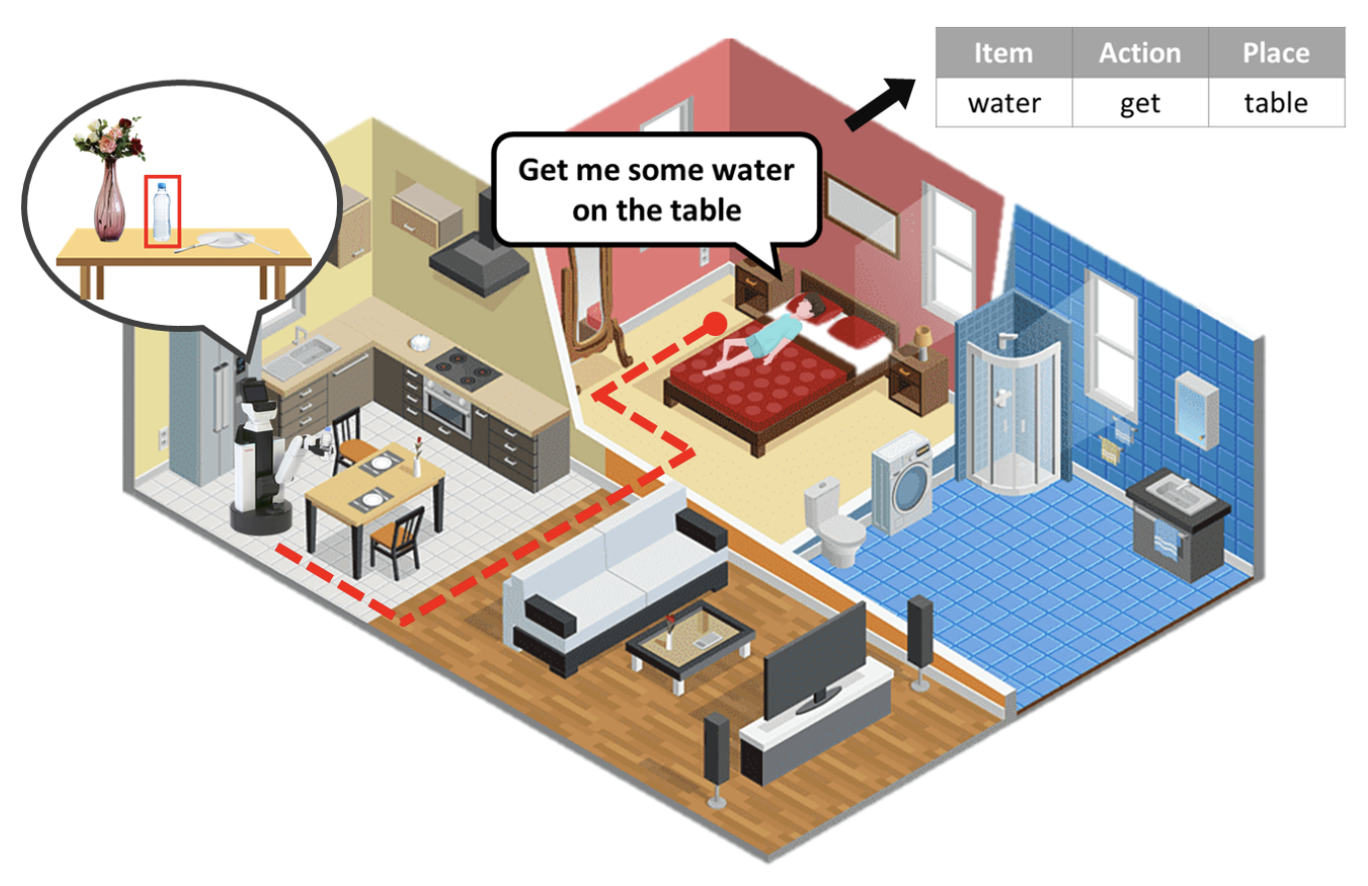 In ICRA 2023 Workshop on Emerging Paradigms for Assistive Robotic Manipulation, 2023* Equal contribution