Team ROBI
Biointelligence Lab, Seoul National University · advisor Prof. Byoung-Tak Zhang

Team ROBI
Team ROBI is a research team of three graduate students — Hye-Jung Yoon, Yesol Park, and Juno Kim — at the Biointelligence Lab, Seoul National University, advised by Prof. Byoung-Tak Zhang.
We work on Embodied AI, Robot Perception, Vision-Language-Action (VLA) models, 3D Scene Understanding, Robot Learning, and Sim2Real Transfer, with a focus on integrating explicit 3D perception with policy learning for robust manipulation and mobile robotics.
See our publications, awards, people, and robots pages to learn more.
Meet our robots.
The robot members of Team ROBI.
-
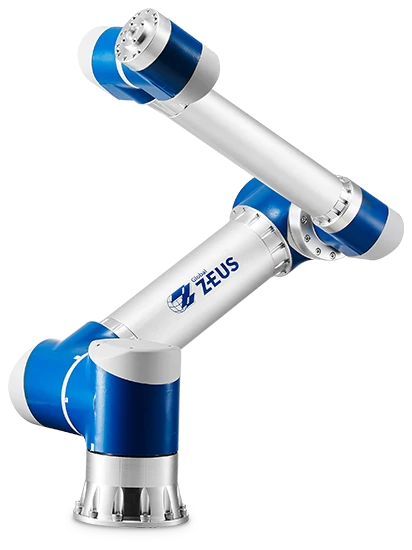
ZEUS
Robot 6-Axis
Industrial arm
-
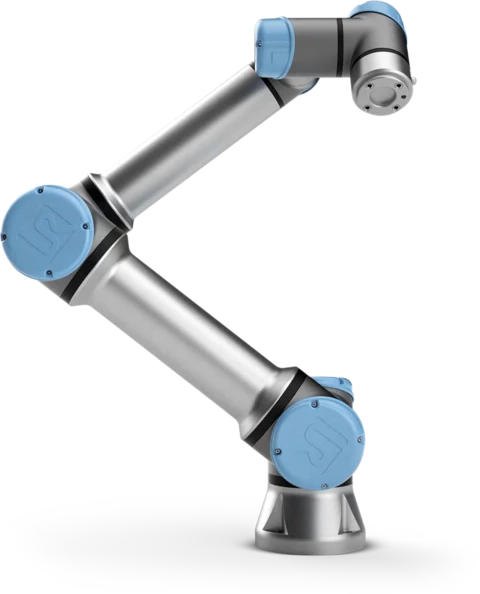
UR5
UR5 / UR5e
Collaborative arm
-
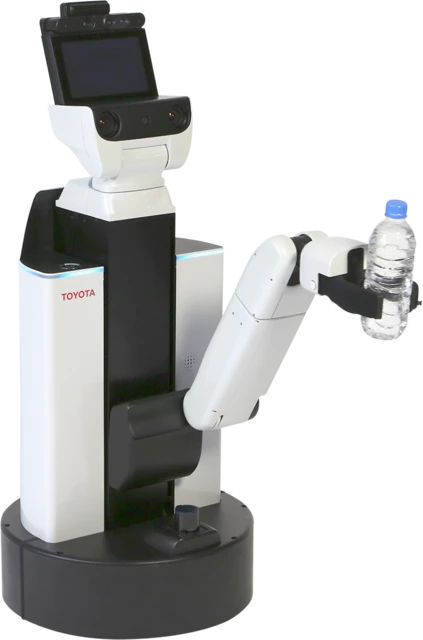
HSR
Toyota
Human support robot
-
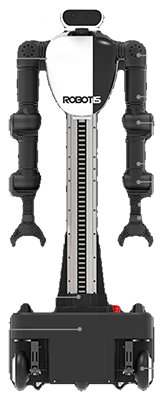
AI-Worker
FFW-SG2
Dual-arm mobile robot
Image credits
ZEUS · Universal Robots · Toyota · ROBOTIS · ROBROS
news
| Oct 2026 | 🎉 Our paper “Head2Wrist: Wrist-Camera Robot Policies from Human Head-Camera Demonstrations without a Scene Scan” has been accepted as a poster at the CoRL 2026 Workshop on UMI Arena (Austin, USA, November 12, 2026). |
|---|---|
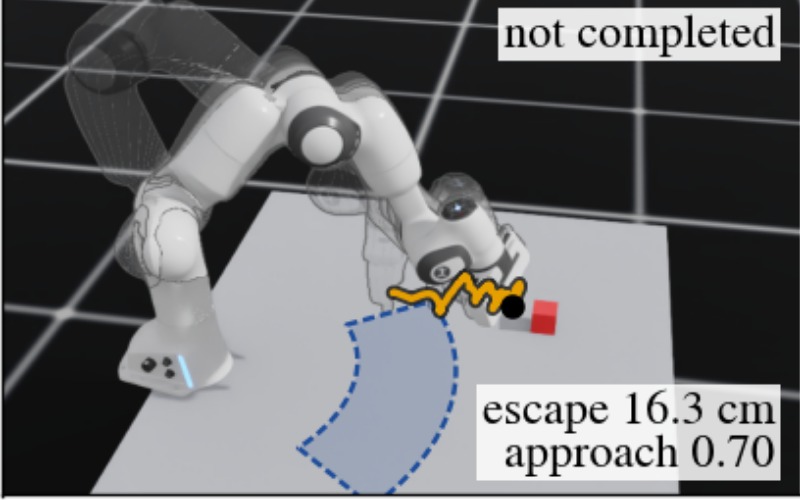
| Oct 2026 | 🎉 Our paper “Escape Is Not Success: Diagnosing Spatial-OOD Failures of Robot Action Interfaces” has been accepted as a poster at the CoRL 2026 Workshop on Everything Beneath the Policy (Austin, USA, November 12, 2026). |
| Jul 2026 | 🏆 We won the Minister of Trade, Industry and Resources Award (1st place) at the 2026 Humanoid AI Challenge. 📰 Press |
| Jun 2026 | 🎉 Our paper “Scene-Q: Confidence-Aware Coarse-to-Fine Querying of 3D Scenes with Selective VLM Reasoning” has been accepted to IROS 2026 (Pittsburgh, USA). |
| May 2026 | 🏆 We won an award at the 2026 AI Co-Scientist Challenge Korea. 📰 Press |
| Oct 2025 | 🎉 Our paper “CDIS: Cross-Dimensional Class-Agnostic 3D Instance Segmentation via 2D Mask Tracking and 3D–2D Projection Merging” was presented at IROS 2025 (Hangzhou, China). |
| May 2025 | 🎉 Our paper “DA-Fusion: Deformable Attention-Based RGB-D Fusion Transformer for Unseen Object Instance Segmentation” was presented at ICRA 2025 (Atlanta, USA). |
| Oct 2024 | 🎉 Our paper “Seg2Grasp: A Robust Modular Suction Grasping in Bin Picking” was presented at IROS 2024 (Abu Dhabi, UAE). See the project page for code, demo footage, and results. |
| Oct 2024 | 🎉 Our paper “Ov-Map: Open-Vocabulary Zero-Shot 3D Instance Segmentation Map for Robots” was presented orally at IROS 2024 (Abu Dhabi, UAE). |
| Jun 2024 | 🏆 We won an award at the 2024 National University Disaster and Safety Data Hackathon. |
| Dec 2023 | 🏆 We won the Minister of Science and ICT Award (1st place) at the AI Competition for Space Radio Disaster Prediction. 📰 Press |
| Jul 2023 | 🏆 We won both the DSPL and OPL leagues at RoboCup@Home. 📰 Press |
| May 2023 | 🎉 Our paper “Visual Perception-Based Assistive Mobile Robot System for Manipulation Tasks” was presented at an ICRA 2023 workshop (London, UK). |
| Nov 2022 | 🏆 We won the Presidential Award (1st place) at the ZEUS Arm-Robot Challenge. 📰 Press |
selected publications
- Research
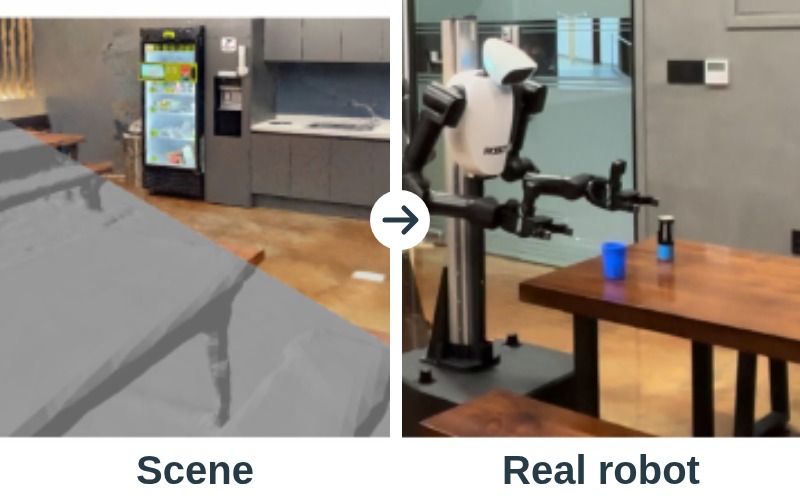 Research project, 2026
- CoRL W
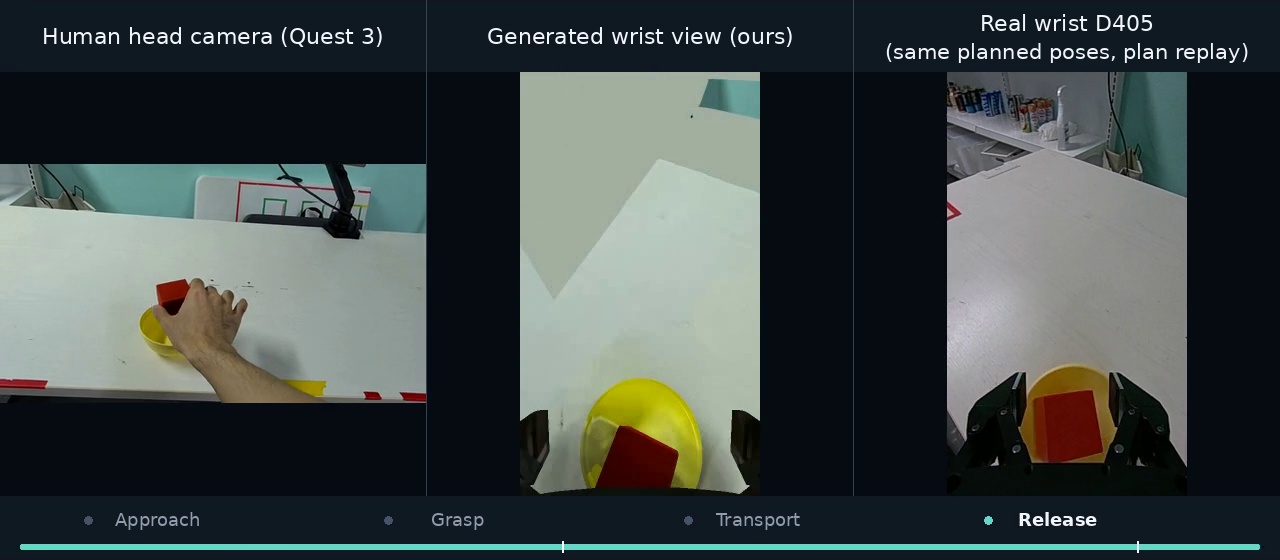 In CoRL Workshop on UMI Arena, 2026
- IROS
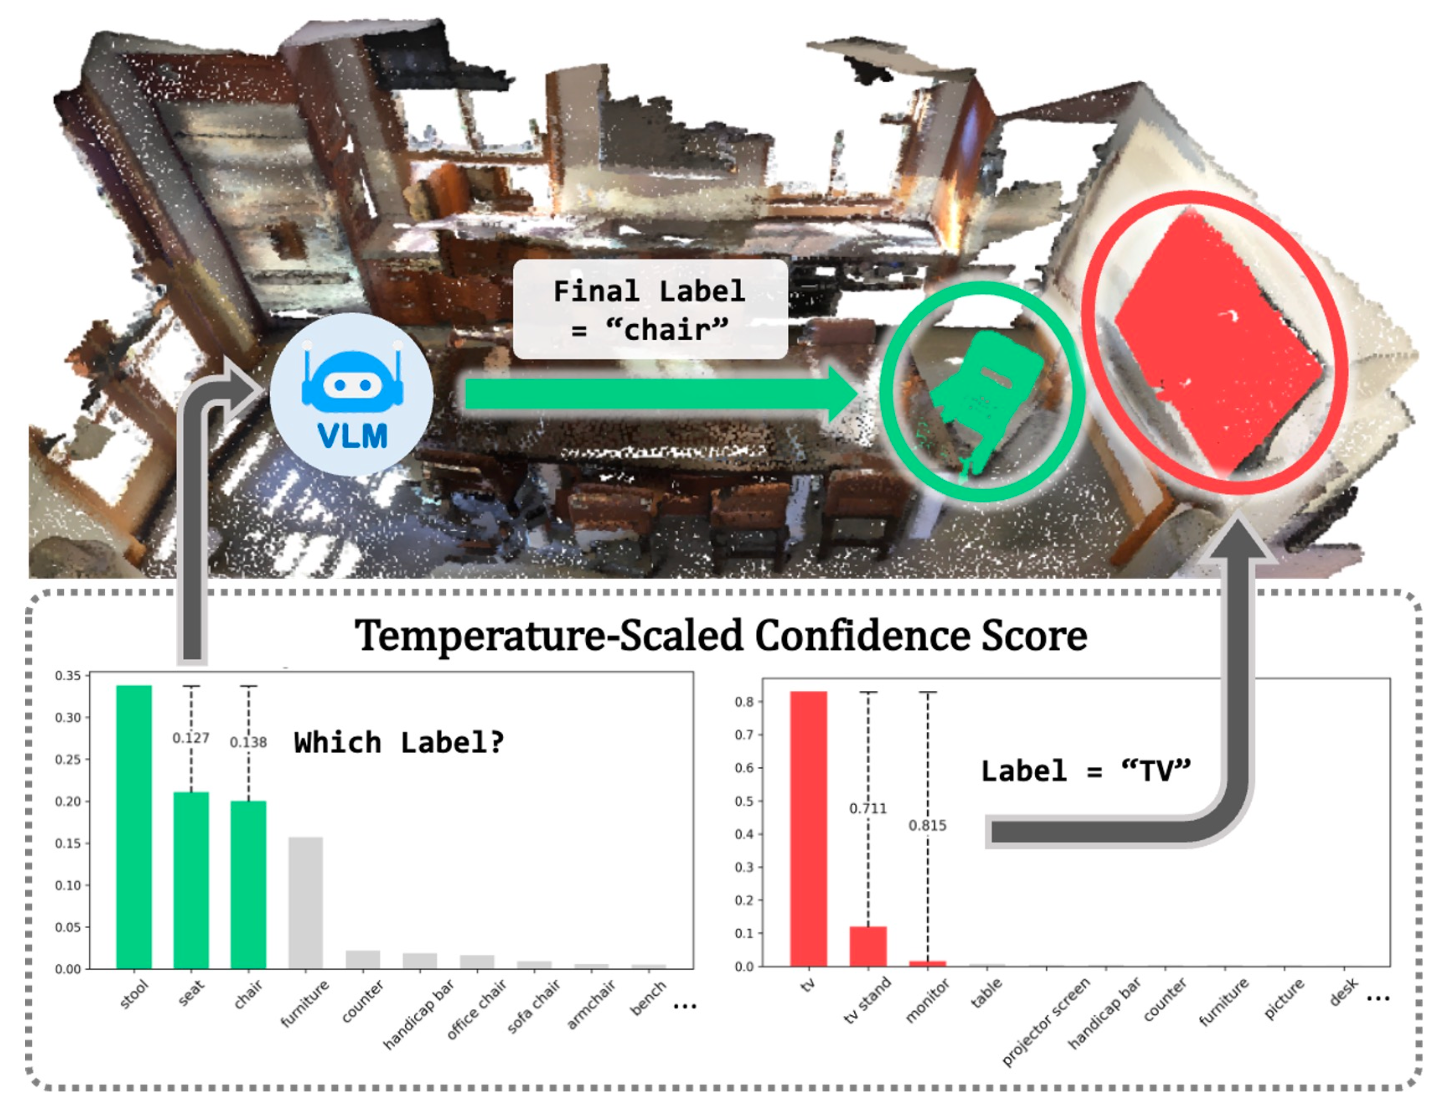 In IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2026* Equal contribution
- IROS
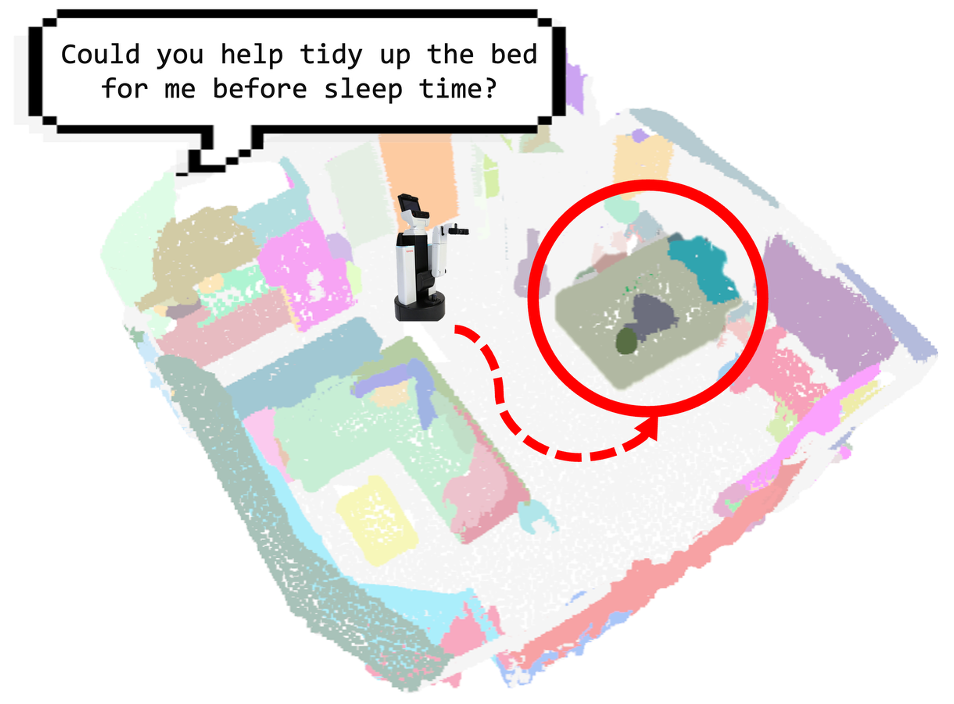 In IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) (Oral), 2024* Equal contribution